
 By Sarah Xiao
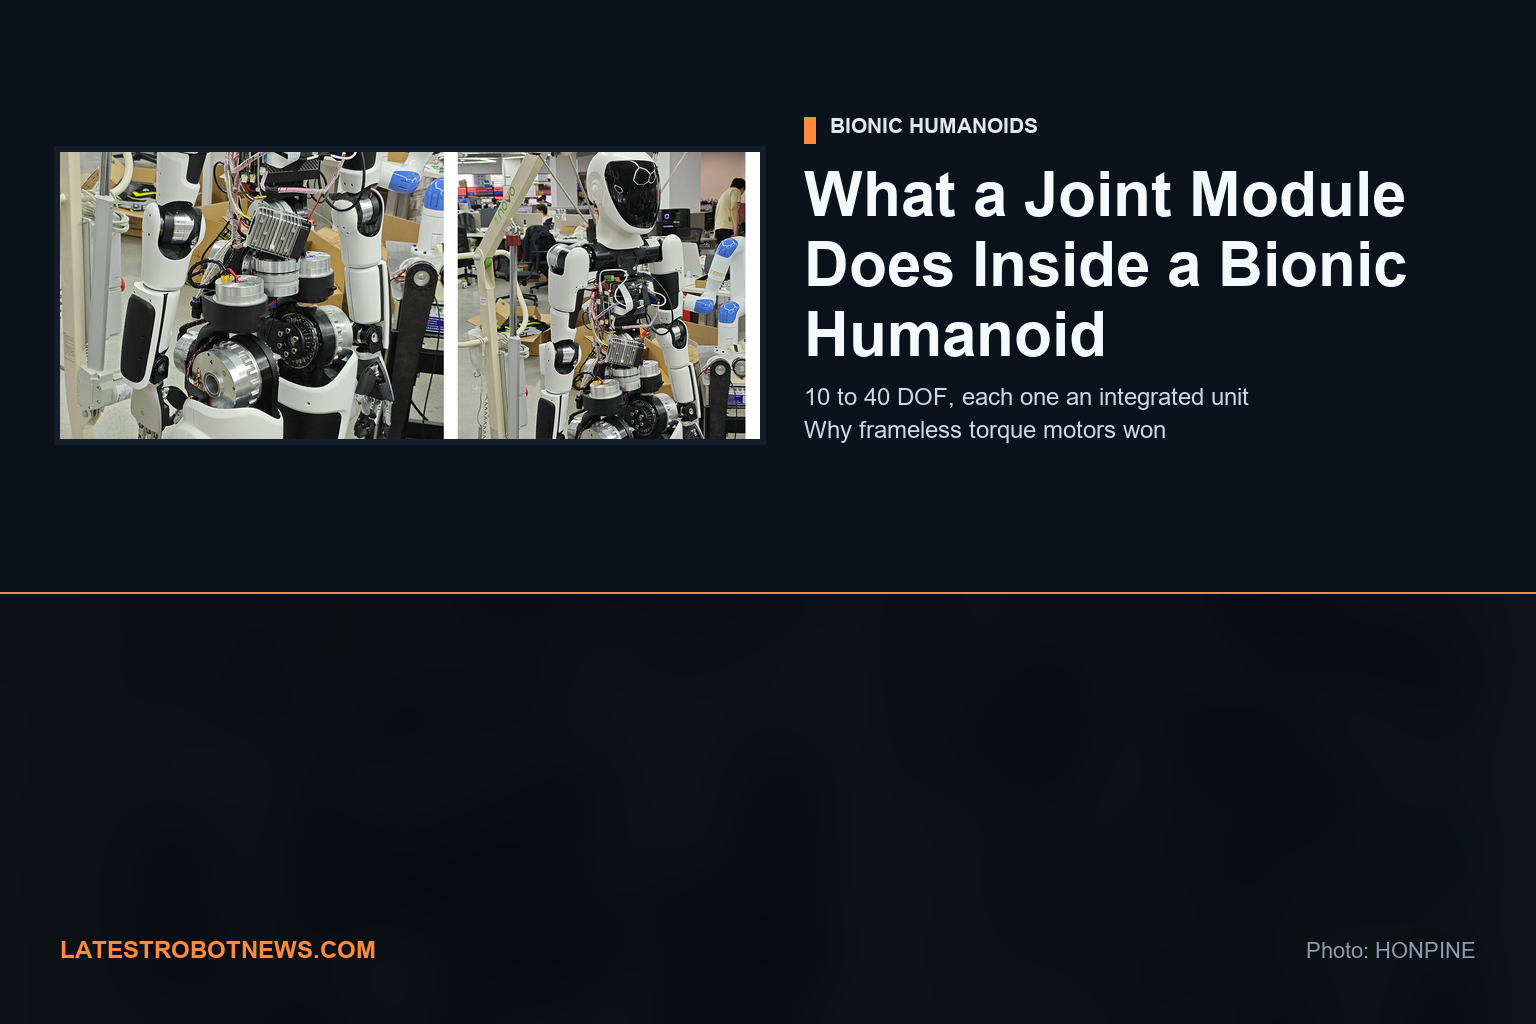
By Theodore Li, Technical Director, HONPINE. Adapted from the original published on honpine.com.
A bionic humanoid is the test case for an entire supply chain: high-precision joint modules, intelligent sensing, high-performance control chips and algorithms all have to work at the same time. A typical platform carries 10 to 40 degrees of freedom, and every one of them is a place where the integration can go wrong.
Modular harmonic joint modules exist to remove that failure surface. But “module” gets used loosely, so it is worth being precise about what is inside one, and why the frameless torque motor is the part that changed everything.
What a bionic humanoid actually asks of a joint
Bionic robots perform operations that a person would otherwise do: handling, assembly, other high-precision work on the industrial side; dancing, opening doors, handing objects on the service side. The common requirement is that they move the way a living organism moves — flexibly, coordinated, and safely.
That translates into joint requirements that are easy to state and hard to satisfy simultaneously:
- High torque density — enough torque within the space the joint can occupy
- Compact size — the joint cannot be the reason the arm looks wrong
- Low mass — especially distal, because mass multiplies with arm length
- Stiffness with compliance — rigid enough to hold a position, compliant enough to be safe near a person
A joint that is excellent on three of those and fails the fourth is not a usable joint. This is why the industry moved from “buy a motor and a reducer and bolt them together” to buying an integrated module.
What is inside a joint module
A joint module is a fully integrated unit that pre-packages a motor, a reducer and sensors into one tested and calibrated assembly. The internal components are matched to each other at the factory, which removes the two problems that dominate DIY integration:
- Misalignment. Bearing seats, shaft concentricity and encoder mounting are all set by the module maker, not by the robot builder’s fixture.
- Assembly error. Preload, grease quantity, encoder zeroing and backlash are set once, in a controlled process, and then verified.
The practical consequence is that a bionic robot maker can buy a harmonic joint module and use it directly, which shortens the development cycle and cuts production complexity. The alternative — designing a joint from components — puts the whole calibration burden on the robot team, and that is where schedules die.
The two components that decide the performance
The harmonic reducer
Because of its multi-tooth engagement design, the contact area is large, so the reducer can withstand high torque loads. The structure also provides high torsional rigidity: minimal deformation under load, which means fast system response, accurate positioning, and good vibration resistance.
In practice this is what lets a robot do heavy-load handling or precision machining without visible shaking or position drift. Rigidity in the reducer is what makes the control loop’s job possible.
The frameless torque motor
The core idea is direct drive and high integration. Strip out the housing, bearings and output shaft, keep only the rotor and stator, and integrate them directly into the mechanical structure.
The result is compact, high torque density, high rigidity — ideal for joint modules, because it saves space and mass and allows slimmer limbs and smaller joints. It is also why the modern humanoid arm does not look like a scaled-down industrial arm: there is no gearbox housing to hide.
The module HONPINE builds
Based on the frameless torque motor plus harmonic reducer combination, HONPINE’s current-generation harmonic joint modules are widely used in humanoid actuators. The stated characteristics:
- Extremely high power and torque density
- High positioning accuracy and rigidity
- Compact, lightweight structure
- Higher efficiency, reduced energy loss
Those four are not independent achievements. They come from the same architectural decision: put the motor where the reducer is, instead of putting a motor somewhere else and transmitting power to it.
Why modularity compounds
The argument for modules is not only that they are easier to design in. It is that they make the second robot cheaper than the first.
Once a joint module is calibrated and characterised, its torque curve, backlash and thermal behaviour are known quantities. The next platform that uses it inherits that data. A company building five humanoid variants does not pay the calibration cost five times. That is the compounding effect, and it is the reason a joint module supplier ends up closer to the robot’s roadmap than a component vendor ever gets.
Source: adapted from “How Harmonic Joint Modules Empower the Development of Bionic Humanoid Robots”, originally published by HONPINE at honpine.com. Product characteristics are HONPINE’s. Editing and analysis by Latest Robot News.